Mid- to High-rise Building Site
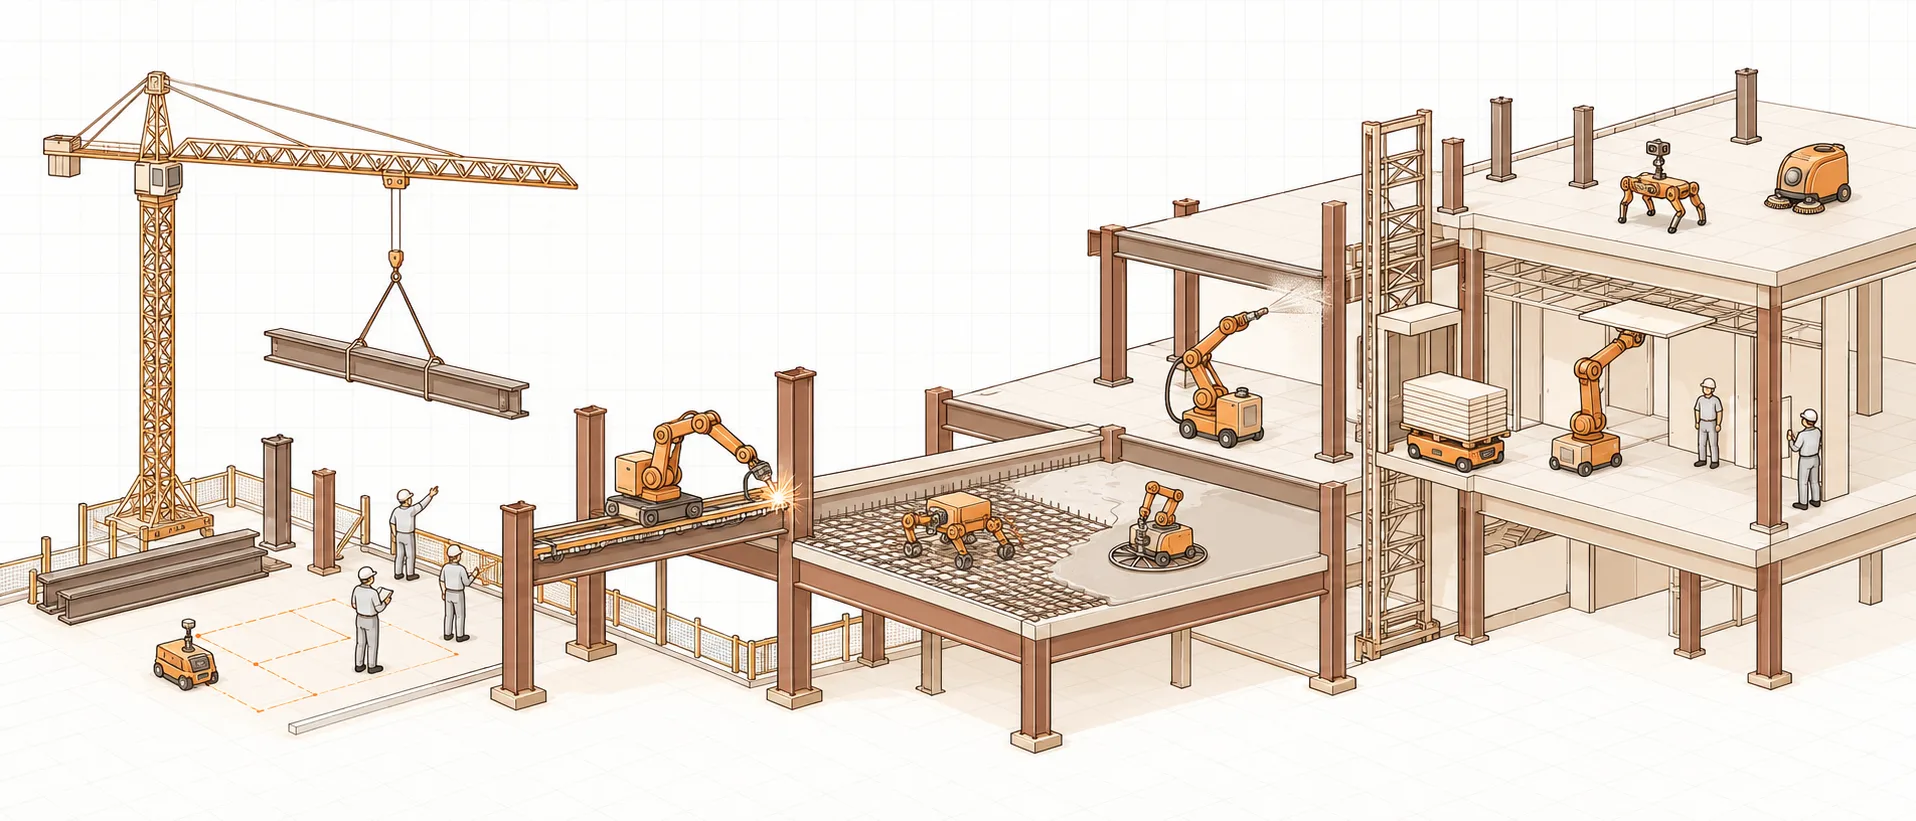
Steel erection, bolting, and curtain-wall installation still belong to cranes and skilled crews, but layout marking, welding, rebar tying, fireproofing, material transport, ceiling boards, patrols, and cleaning are already being handled by robots on major contractors' sites. The big advantage: quadruped robots and humanoids can move through sites built for people, including stairs and construction elevators.
8道工序、19项作业可由机器人替代。
工序流程
点击工序可跳转到对应作业。
工序来源:キャリアマップ「建築工事の流れ」(準備・仮設→基礎→躯体→外装→内装→表層→外構) / freee「躯体工事とは」(墨出し→鉄筋→型枠→配管→打設→養生→脱型) / 福岡市 中間検査・完了検査の流れ(鉄骨建方完了時→耐火被覆・内装・外装) / ビジネス+IT 清水建設 Shimz Smart Site(揚重・搬送/天井・床/柱溶接の省人化試算)
各工序的替代作业
按工序列出人工作业中已有机器人承担实例的项目,可从右侧链接查看候选机型与导入实绩。
- 可机器人化
Surveying & layout marking
Set control points with a total station, then mark wall and MEP positions from drawings on the floor in chalk or ink, repeated per floor and per trade.
- A mobile robot prints CAD/BIM drawings directly on the floor (wall, MEP, and raised-floor positions)
HP SitePrint (Japan launch May 2025; one operator covers 180–300 m²/h). On an MLIT Chugoku road-marking job (Miyagawa Kogyo, FY2025, adjacent case): layout 400→1,080 m/day, crew −62%. Overseas, Skanska used Dusty Robotics for multi-trade layout on a Sutter Health medical building (California, 2023): three months early, $3M under budget.
来源:日本HP ニュースリリース (2025-05-15) / 国交省 中国地方整備局 インフラDX 現場事例 (2025) / BD+C Skanska × Dusty Robotics (2023-08-21)
- Point-by-point marking, such as raised-floor pedestal positions, by a self-propelled robot
Takenaka self-propelled layout robot (Apr 2019): trial at EQ House and an office-building site; 98→33 s per point, mean accuracy under 2 mm, about 4 hours per 100 m².
- 由人承担
Steel erection & bolting
Tower cranes lift columns and beams, ironworkers set them at height and tighten high-strength bolts; an intermediate inspection follows erection.
Crane lifts and ironworkers at height; no published robot cases found (column welding after erection is step 3).
- 可机器人化
On-site steel welding
Welders run multi-pass welds on column splices and beam flanges, chipping slag between passes; a large column can take several days.
- Fully automatic all-around welding of column splices, including groove sensing and slag removal
Shimizu Robo-Welder, Toranomon-Azabudai Block A (Feb 2021): welded 100 mm-thick basement columns, 8→5 welders per column, 14 units on upper floors covering about 15% of weld length. Kajima manipulator-type site welding robot: four sites since 2020; at a Yokohama building (Nov 2024) groove sensing and slag removal made a full column fully automatic.
来源:ニュースイッチ (2021-02-21) / 建設機械施工 2025-05 鹿島 新工法紹介 / ロボスタ/livedoor (2024-11-11)
- Robotic site welding of beam-column joints, including beam flanges and webs
Obayashi on-site robot welding method (Oct 2017): all six column and beam joints robotized; applied to large beam web splices at the Shinagawa new station project. One operator runs two robots for about 1.5× a welder's output.
- 可机器人化
Rebar, formwork & concrete (floor slabs)
Lay rebar on deck plates and tie every intersection, then pour concrete and finish the slab with trowels; long hours bent over.
- A self-propelled robot ties rebar intersections on floor slabs
Ken Robotech Tomorobo, rented to contractors: 69 sites, 269 working days, 95 companies by Mar 2022. Remote-operation trial at the NTT West former HQ redevelopment site (May 2023) shifted 80% of tying work to the robot.
- Trowel finishing of poured concrete floors by a self-propelled robot
Taisei concrete floor-finishing robot (Jun 2017): proven at a Tokyo site, 3–4× a finisher's output, about 90 kg so it fits in a construction hoist; two units deployed, with lease and sales to follow.
- 可机器人化
Fireproofing spray
Spray rock wool onto steel beams (semi-dry method). Dusty work in protective gear, three-person crews doing about 100 m² a day.
- Automatic rock-wool spraying over the full beam section (mobile base plus multi-axis arm)
Obayashi fireproofing robot No. 2 at a Tokyo site (from Nov 2023): over 9,000 m² in FY2023. Shimizu Robo-Spray at Toranomon-Azabudai Block A: three workers run two robots for 130 m²/day (about +30%). Kajima at the Omiya Sakuragicho 1-chome project (Jan 2023): a sensor reads beam shapes, removing manual data entry.
来源:大林組 ニュースリリース (2024-01-29) / 建設機械施工 2023-03 清水建設 Robo-Spray / ニュースイッチ (2023-01-25)
- 可机器人化
Material hoisting & transport
Boards and palletized materials go up by construction hoist, then people cart them to the work area; next-day materials are often staged at night.
- Horizontal transport of palletized materials on the work floor and night-time staging in the construction hoist
Shimizu Robo-Carrier: 98% pallet-delivery success at an Osaka high-rise hotel and a large Yokohama site, fleet 8→16 units in FY2019 (Aug 2019). At Toranomon-Azabudai Block A, five units moved 40,000 pallets (Feb 2021).
- Unloading materials from the construction hoist automatically and driving to the set position on a BIM-generated map
Takenaka × Kajima × Aktio material transport robot (2,000 kg payload, announced Dec 2024): automatic delivery verified at an Osaka site in Jul 2024, aimed at break-time and night runs; trials through Apr 2025, rental via Aktio.
- Humanoids carrying materials and moving or patrolling around the site
Shimizu × Noble Machines (US) MOBY humanoid (investment and partnership, Oct 2026): virtual validation of material transport and site patrol within 2026, real-site trials from spring 2027. Company announcement only.
- 可机器人化
Exterior & interior finishing
Exterior: curtain-wall panels are craned into place. Interior: drill the ceiling for hanger bolts, install ceiling and wall boards, then move to joint compound, paint, and flooring.
- Lifting, aligning, and installing system-ceiling boards
Kajima × tmsuk ceiling-board robot with a mobile work platform at a large office building under construction (Jul 2026): two installers' work done by two robots and one installer. Shimizu Robo-Buddy (dual arms hold the board and drive screws) applied at an Osaka building from autumn 2018.
- Drilling and marking ceiling anchor holes for MEP from BIM data
Hilti Jaibot (announced Oct 2020; introduced by Hilti Japan in Feb 2022): localizes with the PLT 300 total station, drills with dust extraction and marks holes per trade. No named customer sites in public sources.
- Autonomous joint-compound application, sanding, and painting of drywall
Okibo × Performance Contracting at Netflix House (Pennsylvania, about 9,300 m², Aug 2025): autonomous work from 3D scans, no scaffold up to 12 ft, up to 5× productivity on Level 4/5 sanding.
- Interior painting by a robot arm that learned from workers' motions
Shimizu AI-robot implementation project (Jul 2026): a robot arm trained by imitation learning paints interiors at Torch Tower, Otemachi, Tokyo.
- Lifting a gypsum board, holding it to the wall, and screwing it in (humanoid)
AIST HRP-5P (182 cm, 101 kg, Sep 2018): at a mock housing site it autonomously carried a 1820×910 mm, 11 kg board and screwed it to the wall with a tool. Research platform; no real-site trial published.
- 可机器人化
Inspection & progress management
Site managers walk the floors daily to take record photos and check as-built, material placement, and safety; some inspections involve measurements such as HVAC airflow.
- A quadruped walks a set route including stairs and captures 360° photos of progress and materials
Takenaka Corp. and Takenaka Civil Spot (Sep 2021): autonomous rounds from floor 1 to 4 at sites in Kanto, Kansai, and Kyushu cut record-photo, progress, and material-management work by about 10%. Taisei's quadruped with T-iInspectionX (Feb 2025) verified stair climbing and obstacle detection at Tokyo-area sites.
- A humanoid carrying a camera patrols the site
Shimizu at Torch Tower (Otemachi, Tokyo, Jul 2026): a humanoid patrols autonomously at 1 m/s holding a camera.
- An autonomous robot measures airflow at HVAC diffusers and generates the report
Kajima airflow-measurement robot (NEDO project started Oct 2025 with Takenaka, Obayashi, and Fujita): BIM-linked autonomous inspection and report generation.
- 可机器人化
Cleaning & housekeeping
Between tasks and after hours, sweep up nails, dust, and board scraps on each floor; the type and size of debris changes with each stage.
- Autonomous floor cleaning on work floors (nails, dust, board scraps)
Taisei: first Japanese deployment of Kaercher KIRA B 50 (Jul 2024) after multi-site trials, alongside its own T-CleanX. Daiwa House, Daiwa Lease, and Fujita: site cleaning robot (about 70 kg, splits into four for carrying, Jul 2022), 30 units across the three firms in FY2023.
来源:LOGISTICS TODAY (2024-07-09) / 共同通信 PR ワイヤー 大和ハウス工業ほか (2022-07-29)
一览
| 工序 | 可由机器人承担的作业 | 阶段 | 机器人类型 | 应用指南 |
|---|---|---|---|---|
| 1. Surveying & layout marking | A mobile robot prints CAD/BIM drawings directly on the floor (wall, MEP, and raised-floor positions) | 日本已导入 | 野外作业 | Surveying & Layout |
| 1. Surveying & layout marking | Point-by-point marking, such as raised-floor pedestal positions, by a self-propelled robot | PoC阶段 | 野外作业 | Surveying & Layout |
| 3. On-site steel welding | Fully automatic all-around welding of column splices, including groove sensing and slag removal | 日本已导入 | 机械臂 | Construction & Assembly |
| 3. On-site steel welding | Robotic site welding of beam-column joints, including beam flanges and webs | 日本已导入 | 机械臂 | Construction & Assembly |
| 4. Rebar, formwork & concrete (floor slabs) | A self-propelled robot ties rebar intersections on floor slabs | 日本已导入 | 野外作业 | Construction & Assembly |
| 4. Rebar, formwork & concrete (floor slabs) | Trowel finishing of poured concrete floors by a self-propelled robot | 日本已导入 | 野外作业 | Construction & Assembly |
| 5. Fireproofing spray | Automatic rock-wool spraying over the full beam section (mobile base plus multi-axis arm) | 日本已导入 | 机械臂 | Construction & Assembly |
| 6. Material hoisting & transport | Horizontal transport of palletized materials on the work floor and night-time staging in the construction hoist | 日本已导入 | 自主移动搬运机器人 | Material Transport & Lifting |
| 6. Material hoisting & transport | Unloading materials from the construction hoist automatically and driving to the set position on a BIM-generated map | PoC阶段 | 自主移动搬运机器人 | Material Transport & Lifting |
| 6. Material hoisting & transport | Humanoids carrying materials and moving or patrolling around the site | PoC阶段 | 人形 | Material Transport & Lifting |
| 7. Exterior & interior finishing | Lifting, aligning, and installing system-ceiling boards | 日本已导入 | 机械臂 | Construction & Assembly |
| 7. Exterior & interior finishing | Drilling and marking ceiling anchor holes for MEP from BIM data | 已有产品 | 机械臂 | Construction & Assembly |
| 7. Exterior & interior finishing | Autonomous joint-compound application, sanding, and painting of drywall | 海外有实绩 | 机械臂 | Construction & Assembly |
| 7. Exterior & interior finishing | Interior painting by a robot arm that learned from workers' motions | PoC阶段 | 机械臂 | Construction & Assembly |
| 7. Exterior & interior finishing | Lifting a gypsum board, holding it to the wall, and screwing it in (humanoid) | PoC阶段 | 人形 | Construction & Assembly |
| 8. Inspection & progress management | A quadruped walks a set route including stairs and captures 360° photos of progress and materials | 日本已导入 | 四足机器人 | Surveying & Layout |
| 8. Inspection & progress management | A humanoid carrying a camera patrols the site | PoC阶段 | 人形 | Surveying & Layout |
| 8. Inspection & progress management | An autonomous robot measures airflow at HVAC diffusers and generates the report | PoC阶段 | 野外作业 | Surveying & Layout |
| 9. Cleaning & housekeeping | Autonomous floor cleaning on work floors (nails, dust, board scraps) | 日本已导入 | 清洁机器人 | Cleaning & Sanitation |
导入前的确认点
- Construction-hoist integration: moving materials to work floors requires linking hoist control and a transport-booking system to the robot (Takenaka × Kajima RPF / JHS app).
- Localization: layout and drilling robots rely on a robotic total station (supported Leica / Trimble / Topcon models); transport and patrol use LiDAR against BIM-derived maps. Check what total stations and BIM you already have.
- A site changes daily: partitions and materials alter yesterday's route. Verify in trials that the robot stops safely at unmapped obstacles and keeps patrolling.
- Equipment weight and portability: welding rails are about 10 kg per piece, floor finishers about 90 kg, cleaning robots split into four; plan for floors without a hoist and for relocation time.
- Off-hours operation: transport and welding pay off at night and during breaks. Decide on guarding, interlocks, weather enclosures (Kajima's unit tent), and who supervises unattended runs.
- Trade-specific machines: welding, rebar tying, fireproofing, and ceiling boards each use dedicated robots; no general-purpose model exists yet. Contractor-developed units come through rental partners (e.g., Aktio) or the Construction RX Consortium working groups.
咨询从贵司哪道工序开始替代
带上贵司的工序表,我们将一起梳理易于替代的作业、候选机型与 PoC 推进方式。