Useful For
Linked to use-case tags, so you can picture post-deployment tasks.
dexterous manipulation
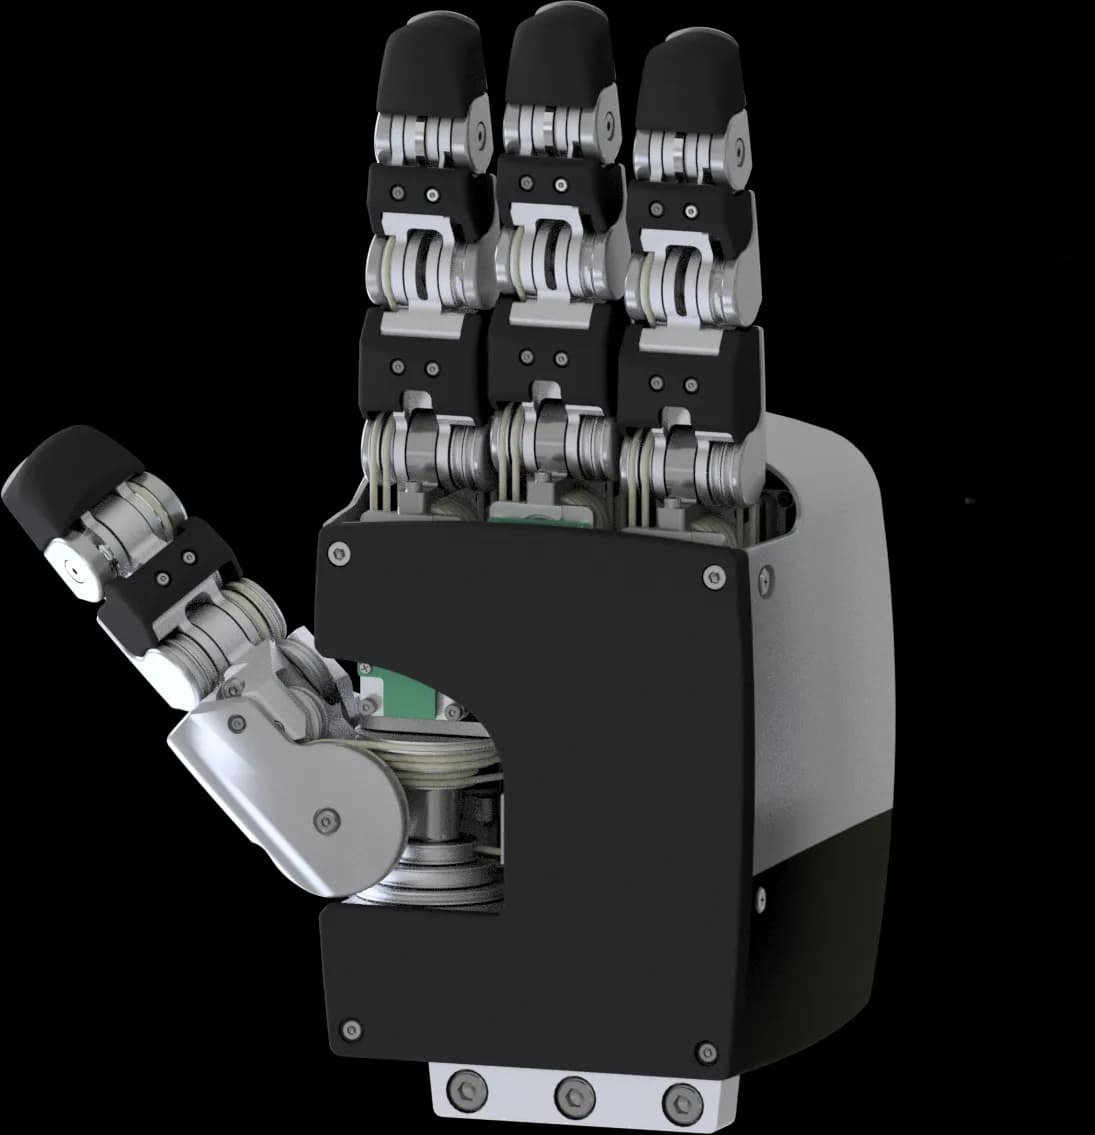
人間の手に近いサイズと構成を持つ、力覚・触覚フィードバック搭載の多指ロボットハンド
teleoperation
人間の手に近いサイズと構成を持つ、力覚・触覚フィードバック搭載の多指ロボットハンド
research
人間の手に近いサイズと構成を持つ、力覚・触覚フィードバック搭載の多指ロボットハンド
Specs
Common Specs
| Maker / Model | Tokyo Robotics Inc. / Torobo Hand |
| Category | Robot Hand |
| Weight | 2 kg |
| Dimensions (L x W x H) | 要確認 |
| Runtime | 要確認 |
| Charge Time | 要確認 |
| Payload | 要確認 |
| Top Speed | 要確認 |
| Connectivity | R / O / S / / c / o / m / p / a / t / i / b / l / e |
| IP Rating | 要確認 |
| Developer Tools | — |
| Offering | Inquiry |
| Reference price | Quote |
Robot Hand Category Specs
| 自由度 | 16 |
| 親指先端力 | 10 N |
| 動作電圧 | 24VDC |
| Notes | 12x 13-bit absolute encoder for joint position measurement at each actuated joint 197x Pressure Sensor (42 points in each finger, 38 points in the thumb, 33 points in the palm) |
REC ●
About Tokyo Robotics Inc.
Company Profile
Company details for Tokyo Robotics Inc. are being verified against primary sources before publication.
- Headquarters
- TBD
Certification / Safety / Deployment Conditions
Japan Fit
要確認PSE / radio certification depends on deployment configuration
International Standards
—Confirm CE / FCC etc. in specs
After Support
要確認SLA and periodic checks are designed per deployment
Japan Cases
—Japan cases will be expanded
Reference price
Quote required要確認
Lead Time
要確認Designed for layout and operations
Want to check whether this setup fits your site?
We diagnose fit from a neutral position based on layout, payload, and operating hours.