Research & Development
Physical validation for AGI research, reinforcement learning, bipedal locomotion, and manipulation technology.
应用场景
每个场景都整理了核心功能、客户价值、导入前确认事项与候选机型。
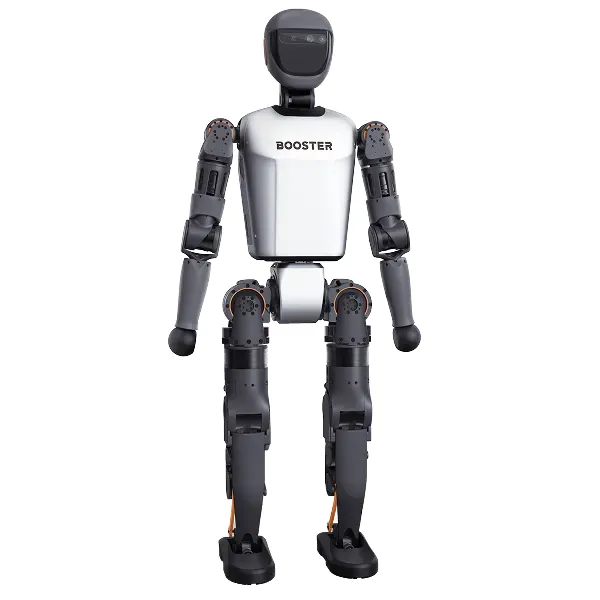
R&D Platforms
Humanoids with open SDKs for locomotion, reinforcement-learning, and embodied-AI research — physical test beds for universities and corporate labs.
查看详情4 款产品 →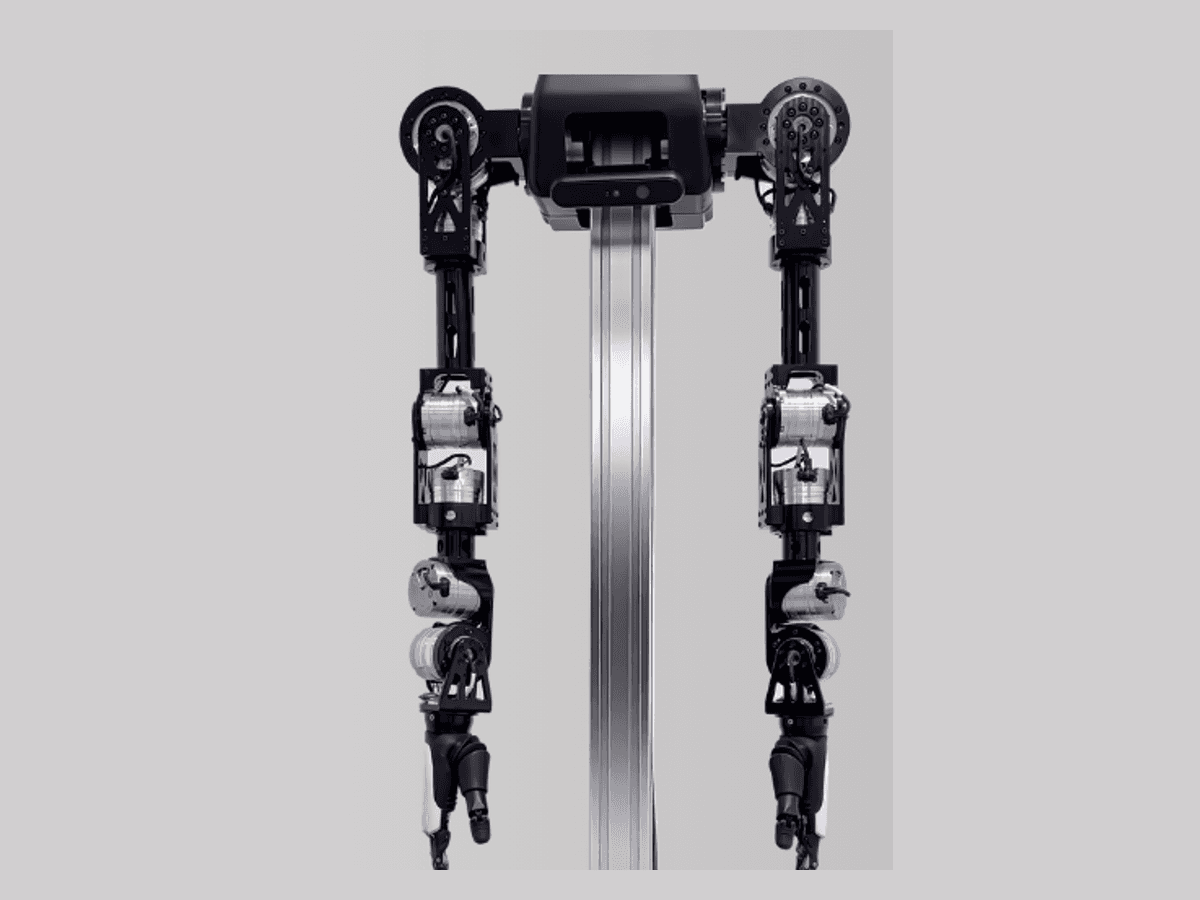
Embodied-AI Data Collection
Demonstrate tasks by teleoperation to collect motion data for robot learning — the foundation for AI models tuned to your own work.
查看详情3 款产品 →
Robot Hands: Research & Special Environments
Multi-finger hands for researching dexterous manipulation through teleoperation, imitation learning, and reinforcement learning — and for testing remote work where people can't easily go.
查看详情4 款产品 →精选候选
精选可在现场实际使用的机型,并附上适用理由。“PoC”表示建议先进行小范围验证的机型。

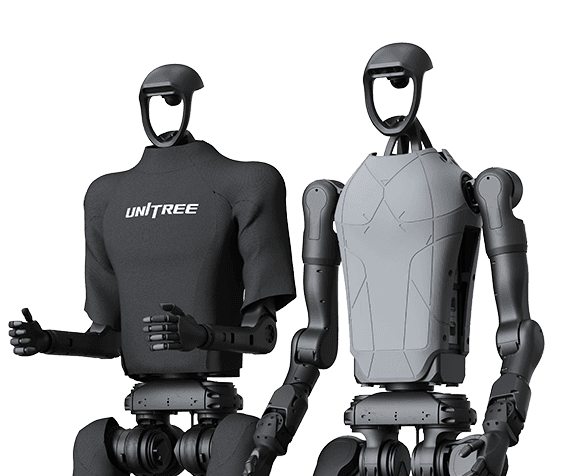
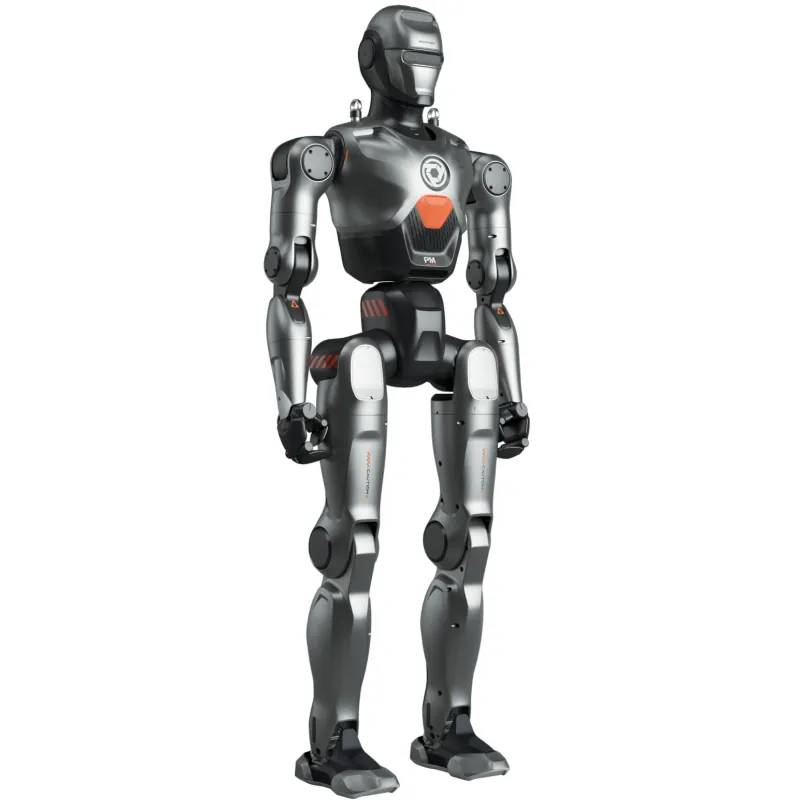
Dual-arm Data Collection Robot
双腕の力伝達と手首カメラを備え、LeRobot V2.0/V2.1/V3.0データセットに対応する数采ロボット。
Dual-arm setup with wrist cameras and LeRobot-format support, built for data collection.
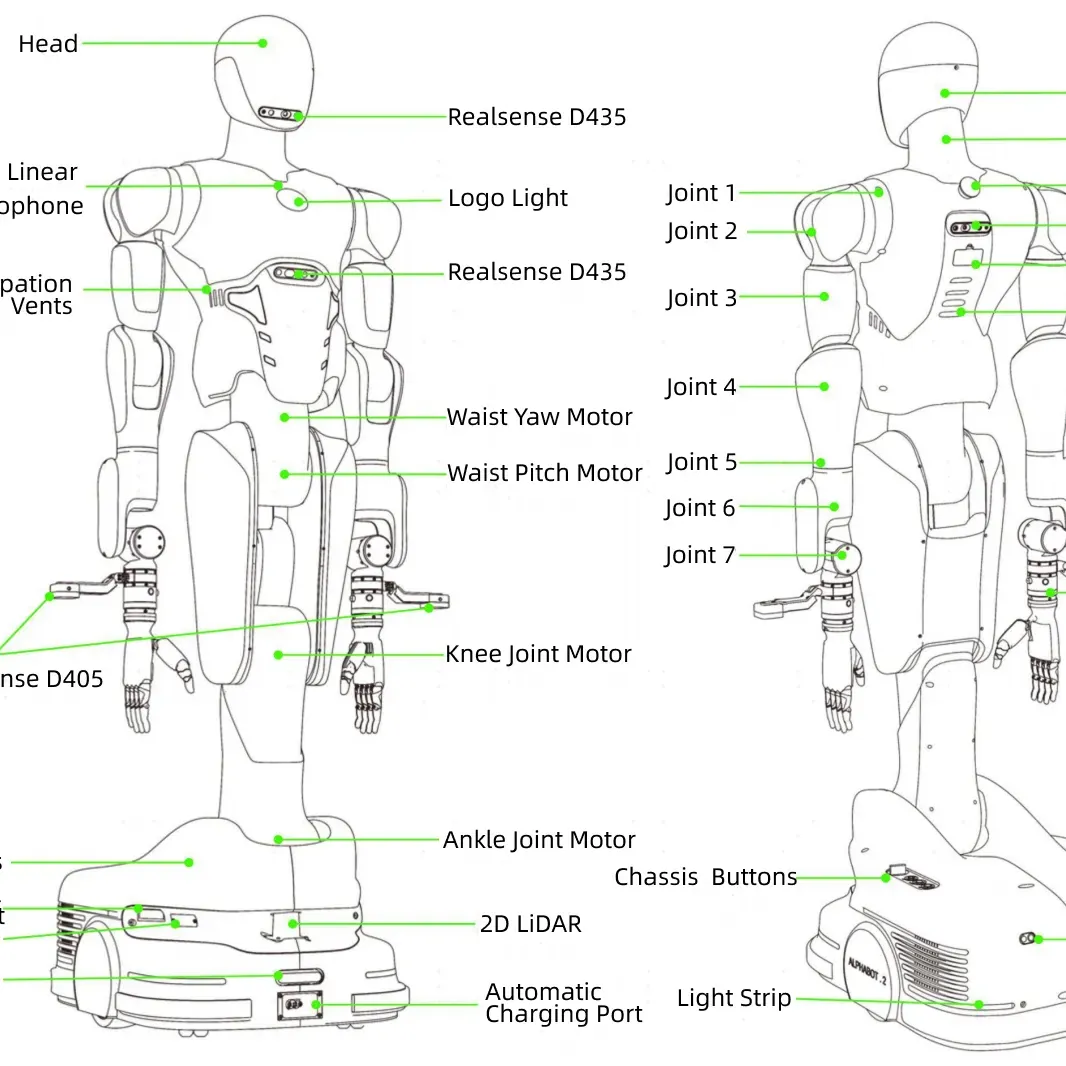
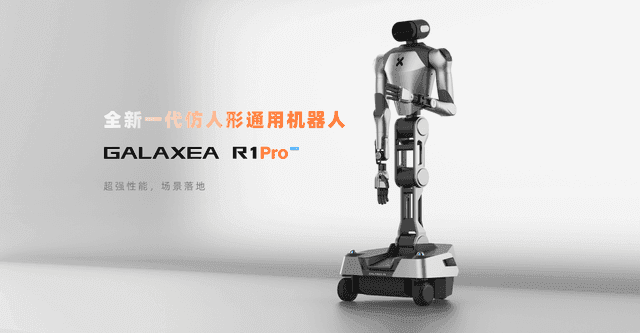
R1 Pro
移動操作・ピッキングPoC向け輪式双腕ロボット
Wheeled dual-arm for mobile-manipulation and picking PoCs; collect data in near-real conditions.
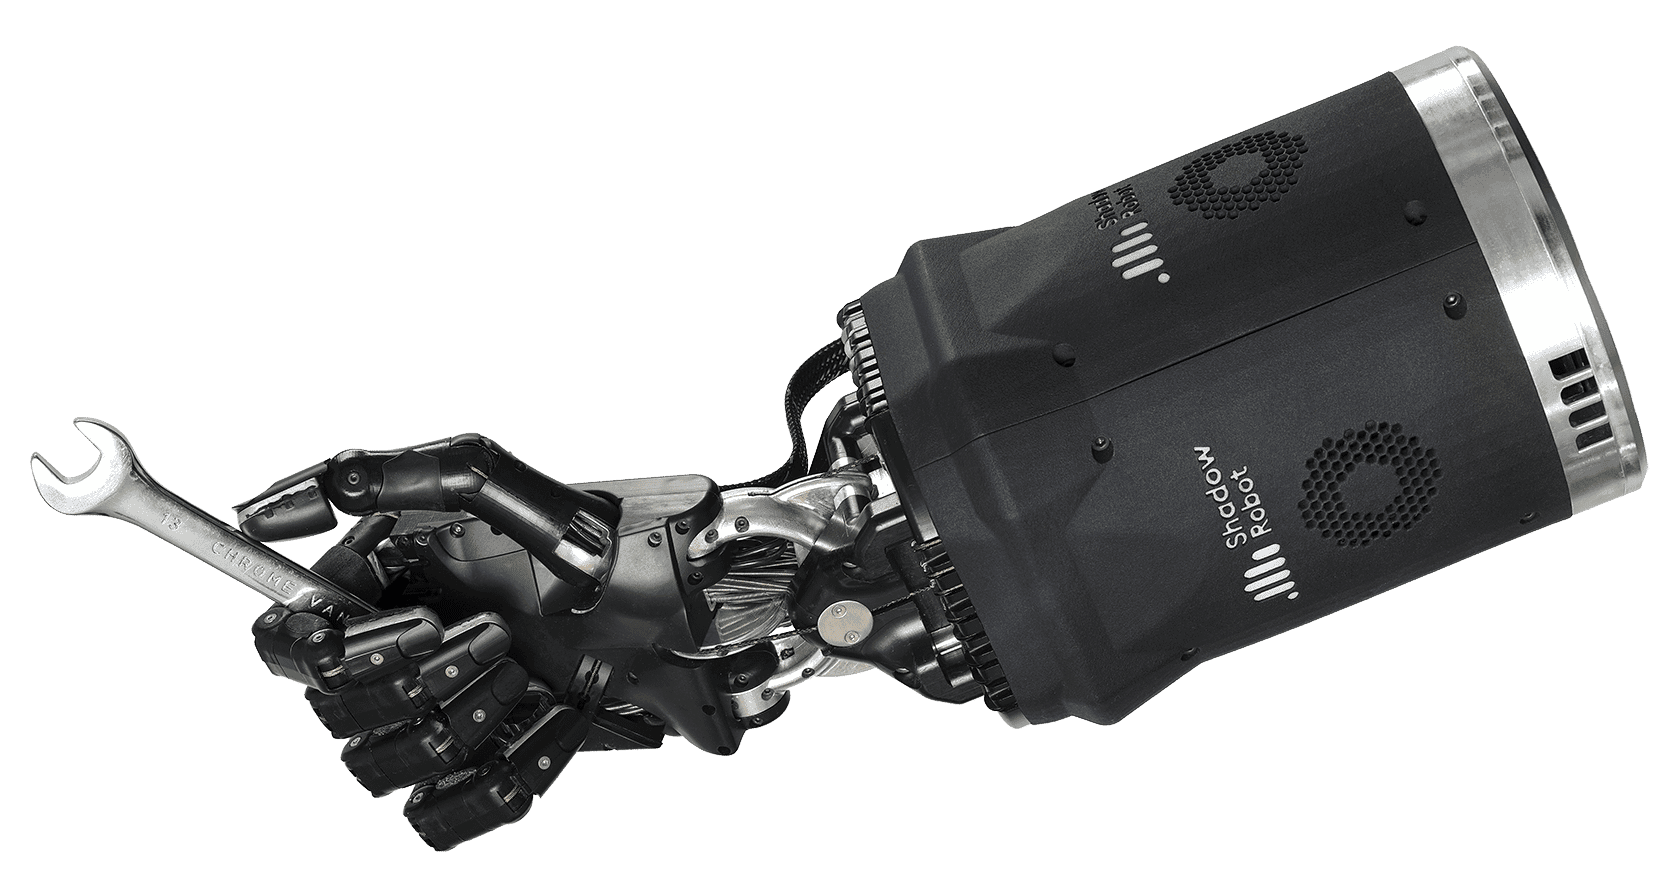
Shadow Dexterous Hand
20モーター・24関節と100超のセンサーを備え、1kHz制御に対応する5指ロボットハンド。
20 motors, 24 joints, 100+ sensors; the standard at research labs worldwide.
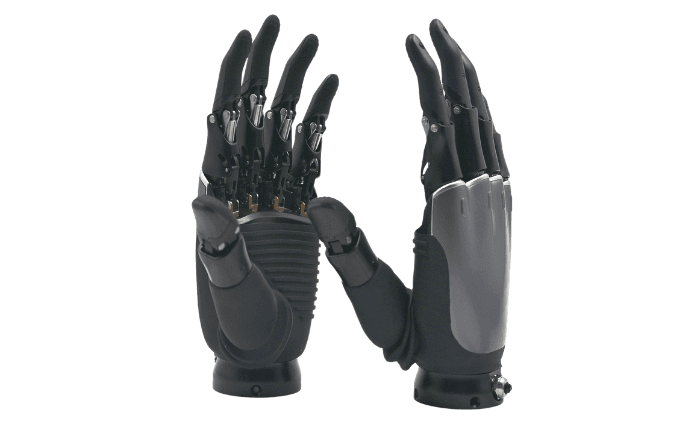
ROH-AP002
指・掌の3次元力覚と150Hz触覚更新に対応する11関節ロボットハンド。
3D force on fingers and palm with 150 Hz touch; an accessible start for tactile research.
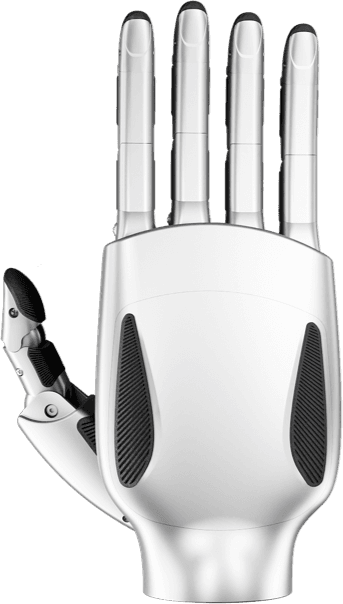
Linker Hand L20
16能動+5受動自由度、触覚・視覚拡張に対応する多指ハンド。
16 active DoF with tactile and vision options; for teleoperation and data collection.
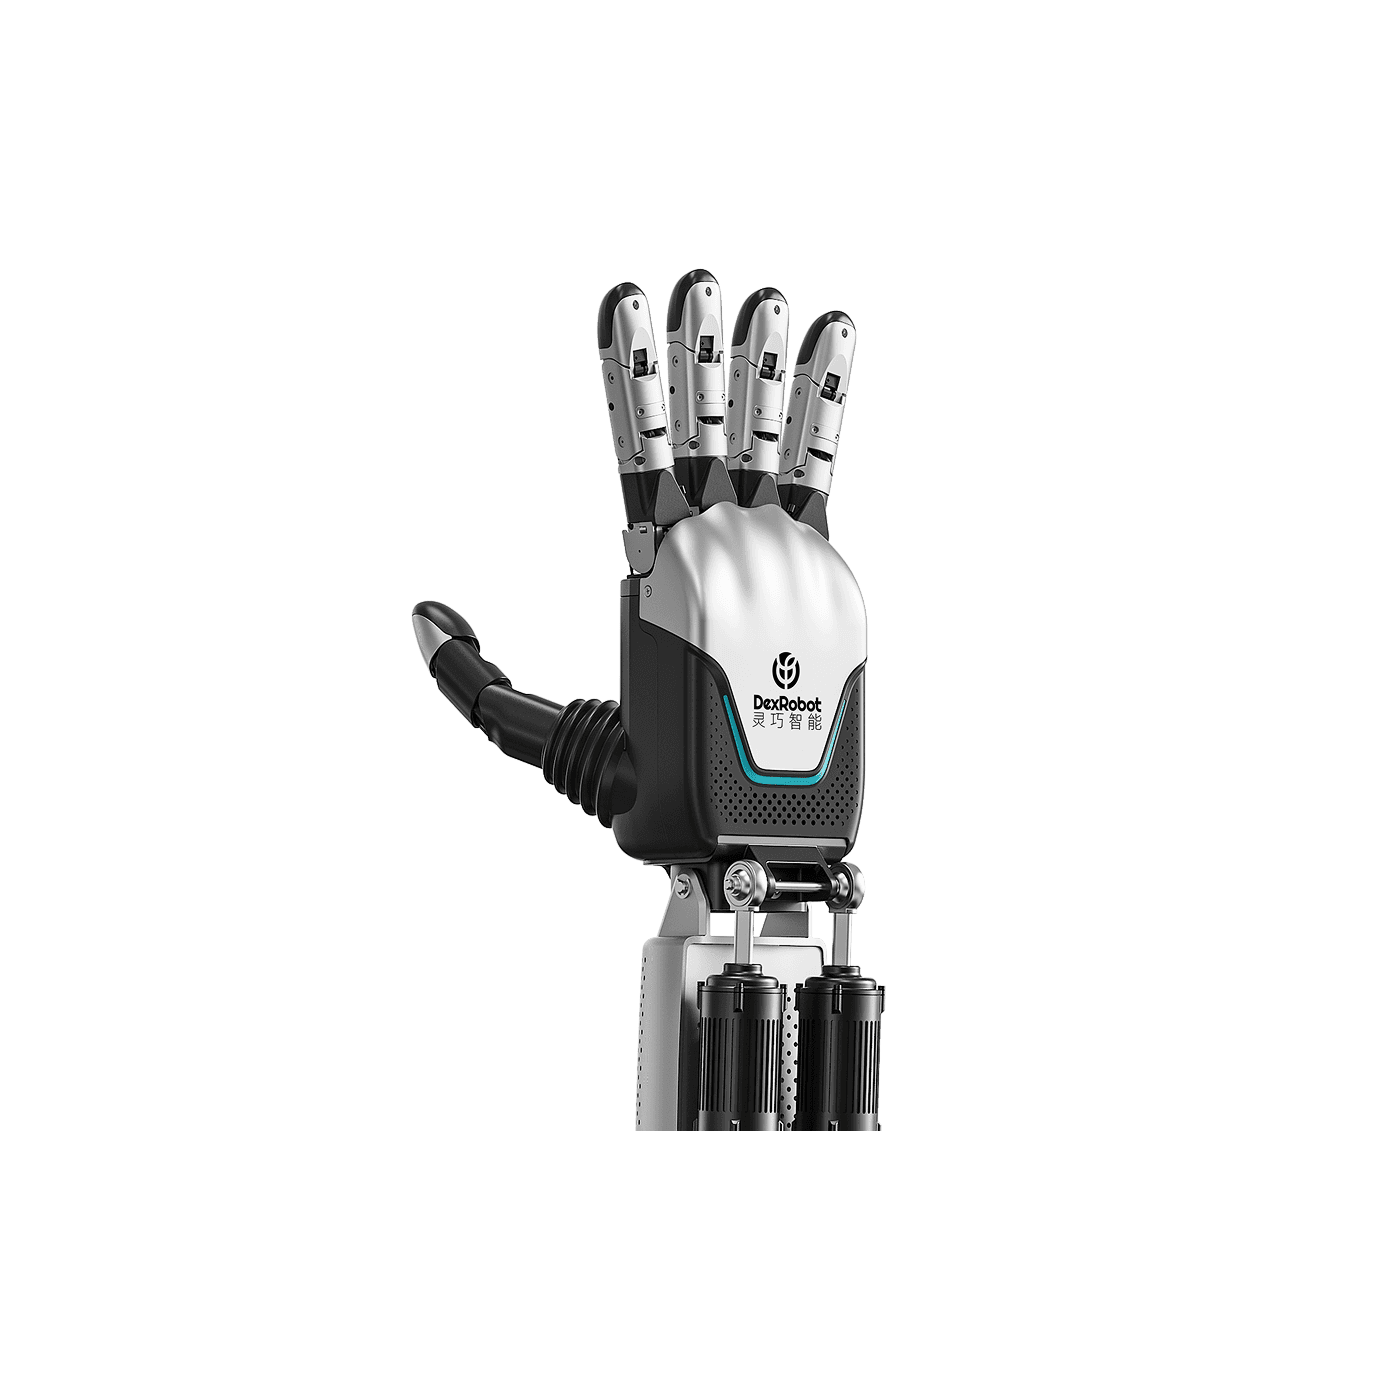
DexHand021 Pro
手首一体構造と全域マルチモーダル知覚を備えた22自由度ロボットハンド。
Wrist-integrated, 22 DoF with full-coverage multimodal sensing for advanced dexterity research.
日本国内实绩
海外案例
咨询适合贵司现场的机型
我们将根据业务内容与运行环境,协助筛选候选机型并规划 PoC。