应用场景 / H Research, Development & Education · Robot Hands Feature
Robot Hands: Research & Special Environments
Multi-finger hands for researching dexterous manipulation through teleoperation, imitation learning, and reinforcement learning — and for testing remote work where people can't easily go.
核心功能
- Human-like dexterity from 20+ joints and dense sensing
- High-rate tactile and force data capture
- Teleoperation and demo collection with data gloves and similar
客户价值
- Validate grasping and manipulation research on real hardware
- Build your own tactile and force datasets for learning
- Assess remote work in hazardous environments ahead of time
导入前需确认
- Required DoF, sensor types, and control rate
- ROS / Python environment and maintenance contacts
精选候选
精选可在现场实际使用的机型,并附上适用理由。“PoC”表示建议先进行小范围验证的机型。
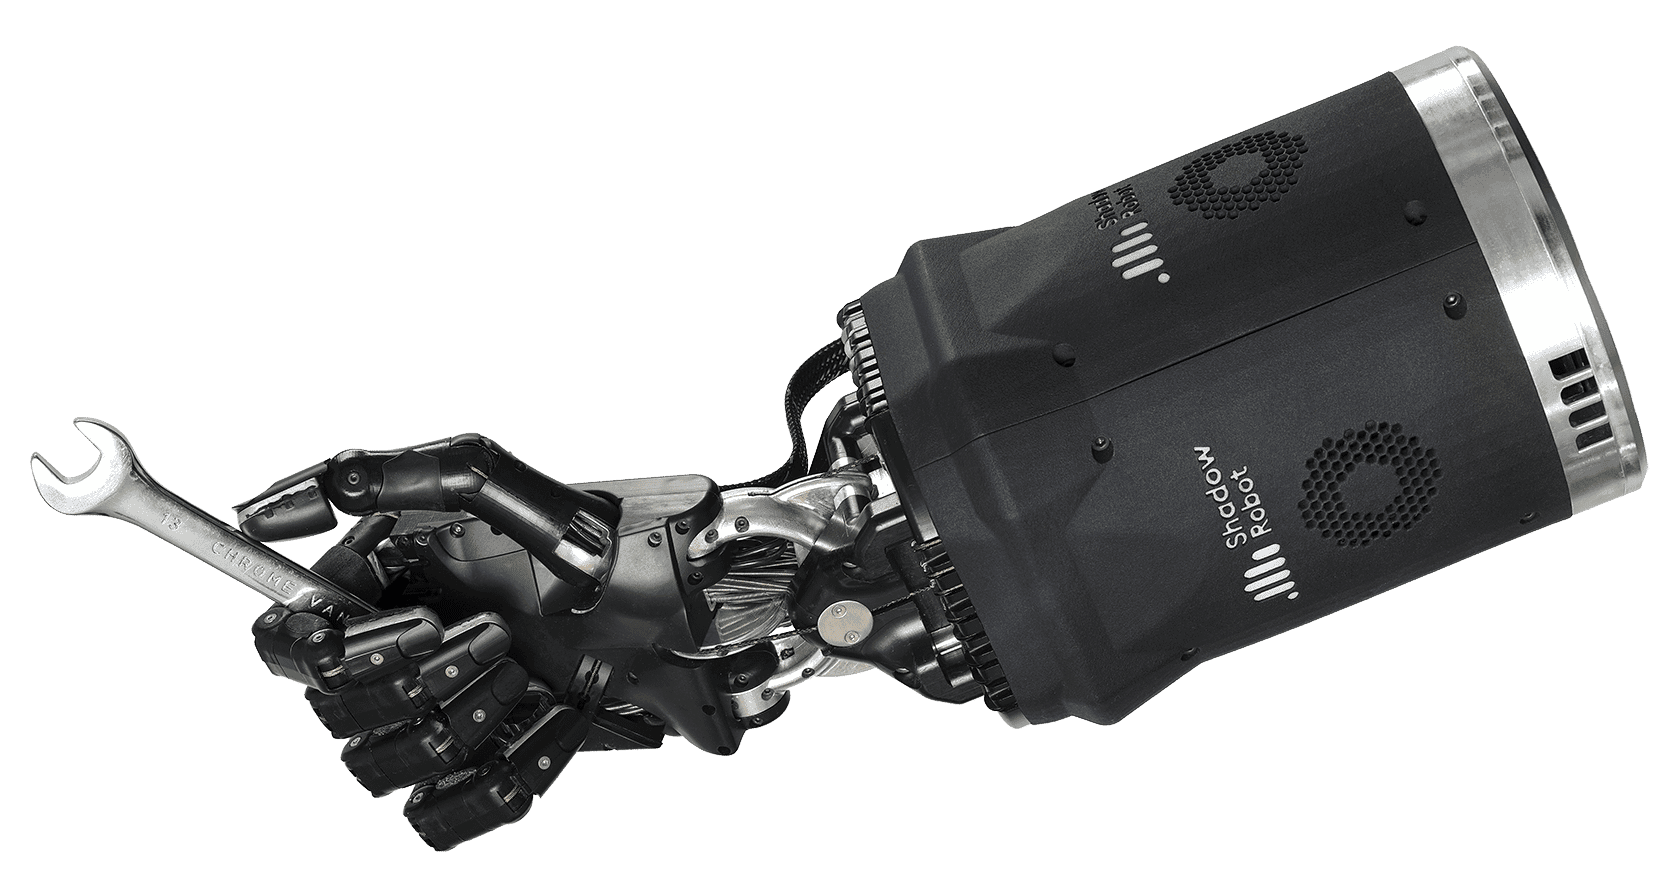
机械手
Shadow Robot
Shadow Dexterous Hand
20モーター・24関節と100超のセンサーを備え、1kHz制御に対応する5指ロボットハンド。
20 Actuated + 4 Under-actuated自由度
已实用
20 motors, 24 joints, 100+ sensors; the standard at research labs worldwide.
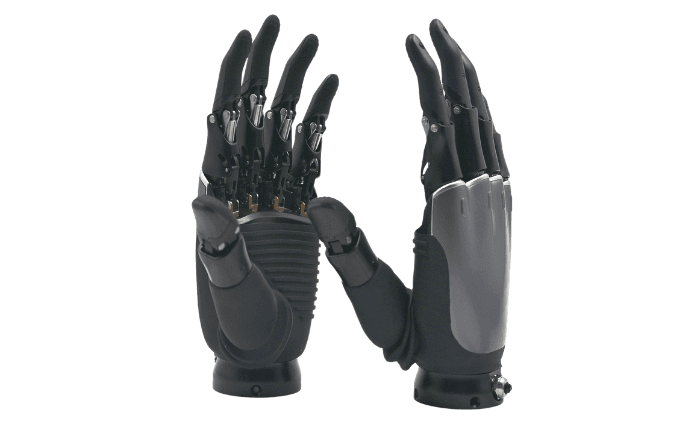
机械手
OYMotion(傲意科技)
ROH-AP002
指・掌の3次元力覚と150Hz触覚更新に対応する11関節ロボットハンド。
最大荷重30kg
已实用
3D force on fingers and palm with 150 Hz touch; an accessible start for tactile research.
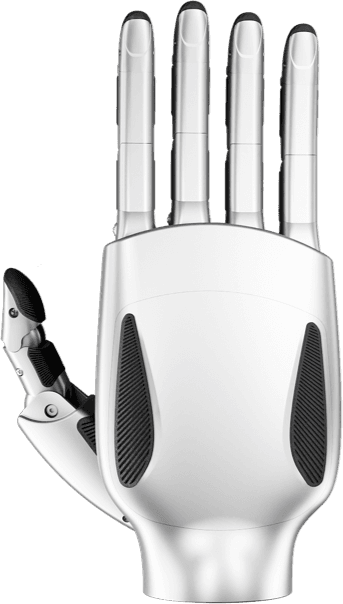
机械手
Linkerbot(灵心巧手)
Linker Hand L20
16能動+5受動自由度、触覚・視覚拡張に対応する多指ハンド。
16 Active + 5 Passive自由度 · 最大荷重20kg · 四指15N
PoC
16 active DoF with tactile and vision options; for teleoperation and data collection.
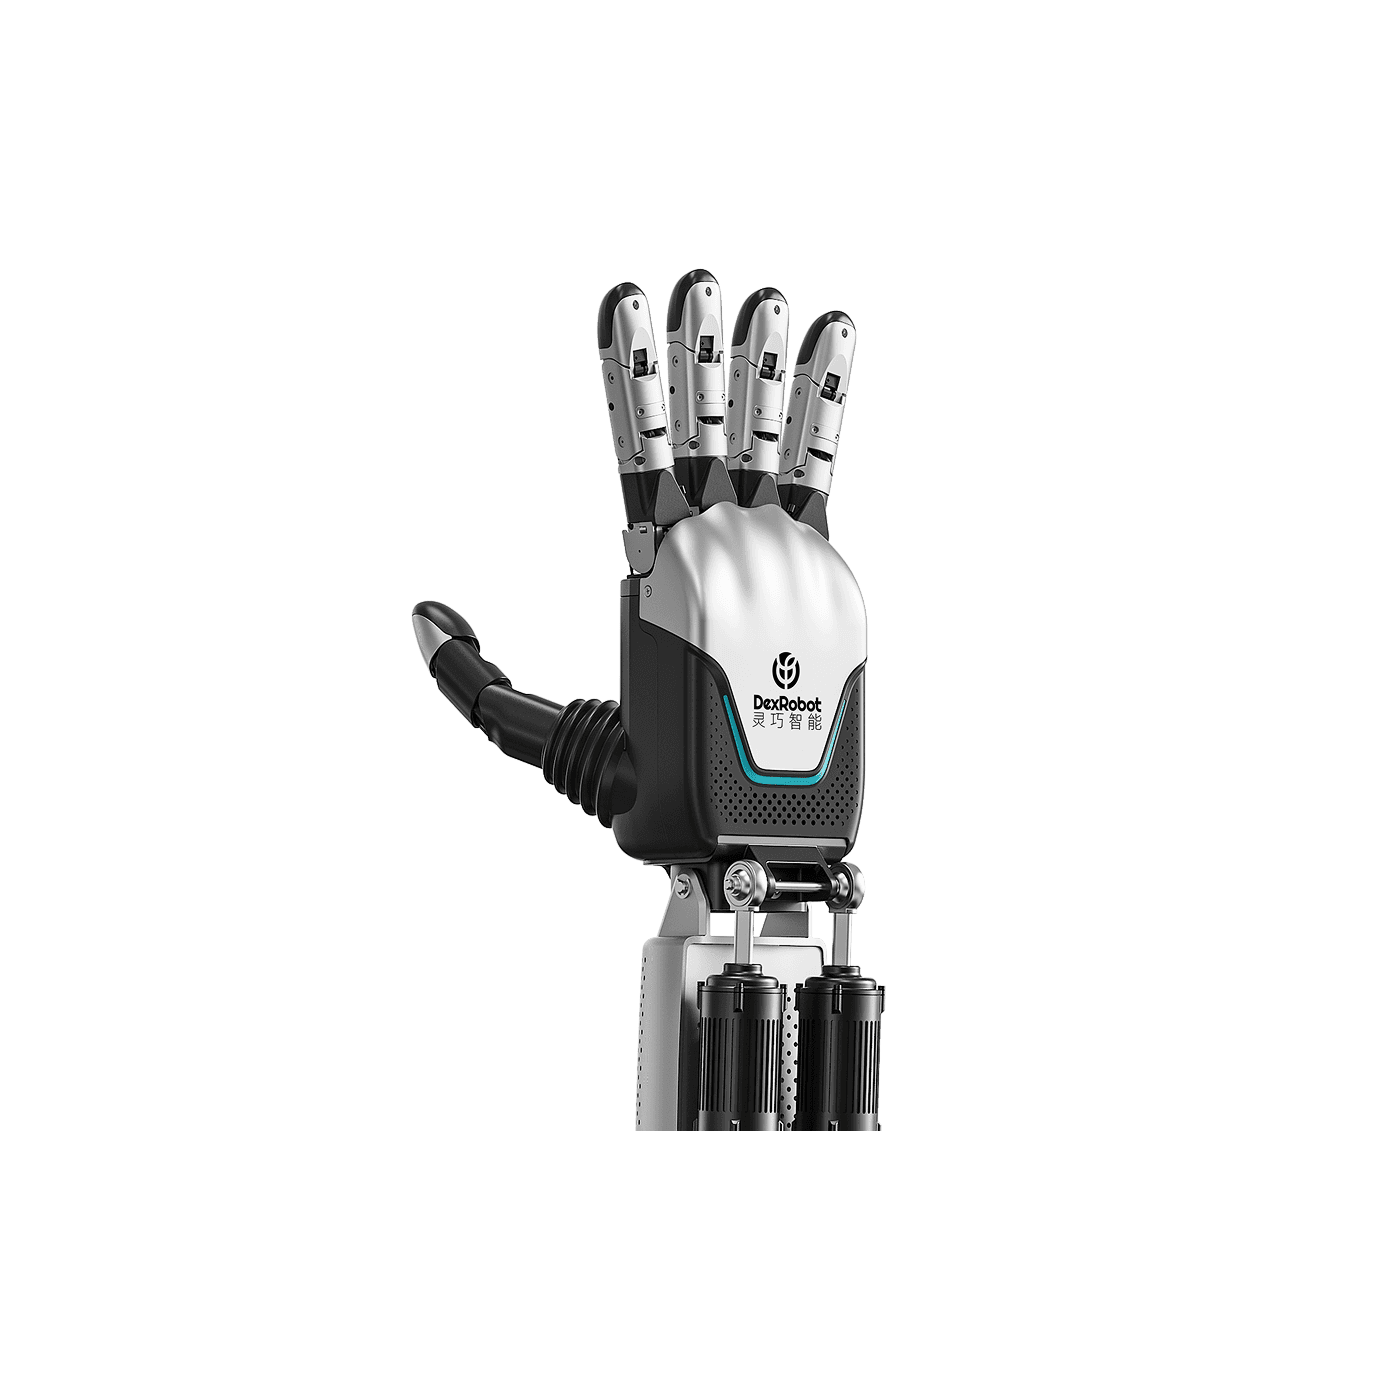
机械手
DexRobot(灵巧智能)
DexHand021 Pro
手首一体構造と全域マルチモーダル知覚を備えた22自由度ロボットハンド。
22自由度 · 最大荷重5kg
PoC
Wrist-integrated, 22 DoF with full-coverage multimodal sensing for advanced dexterity research.
咨询哪款机型更合适
我们将根据现场条件,协助筛选候选机型并规划 PoC。