Robot Hands: Research & Special Environments
Multi-finger hands for researching dexterous manipulation through teleoperation, imitation learning, and reinforcement learning — and for testing remote work where people can't easily go.
- Human-like dexterity from 20+ joints and dense sensing
- High-rate tactile and force data capture
- Teleoperation and demo collection with data gloves and similar
- Validate grasping and manipulation research on real hardware
- Build your own tactile and force datasets for learning
- Assess remote work in hazardous environments ahead of time
- Required DoF, sensor types, and control rate
- ROS / Python environment and maintenance contacts
Selected Robots
Hand-picked for this work, with the reason each one fits. "PoC" marks robots to validate in a limited trial first.
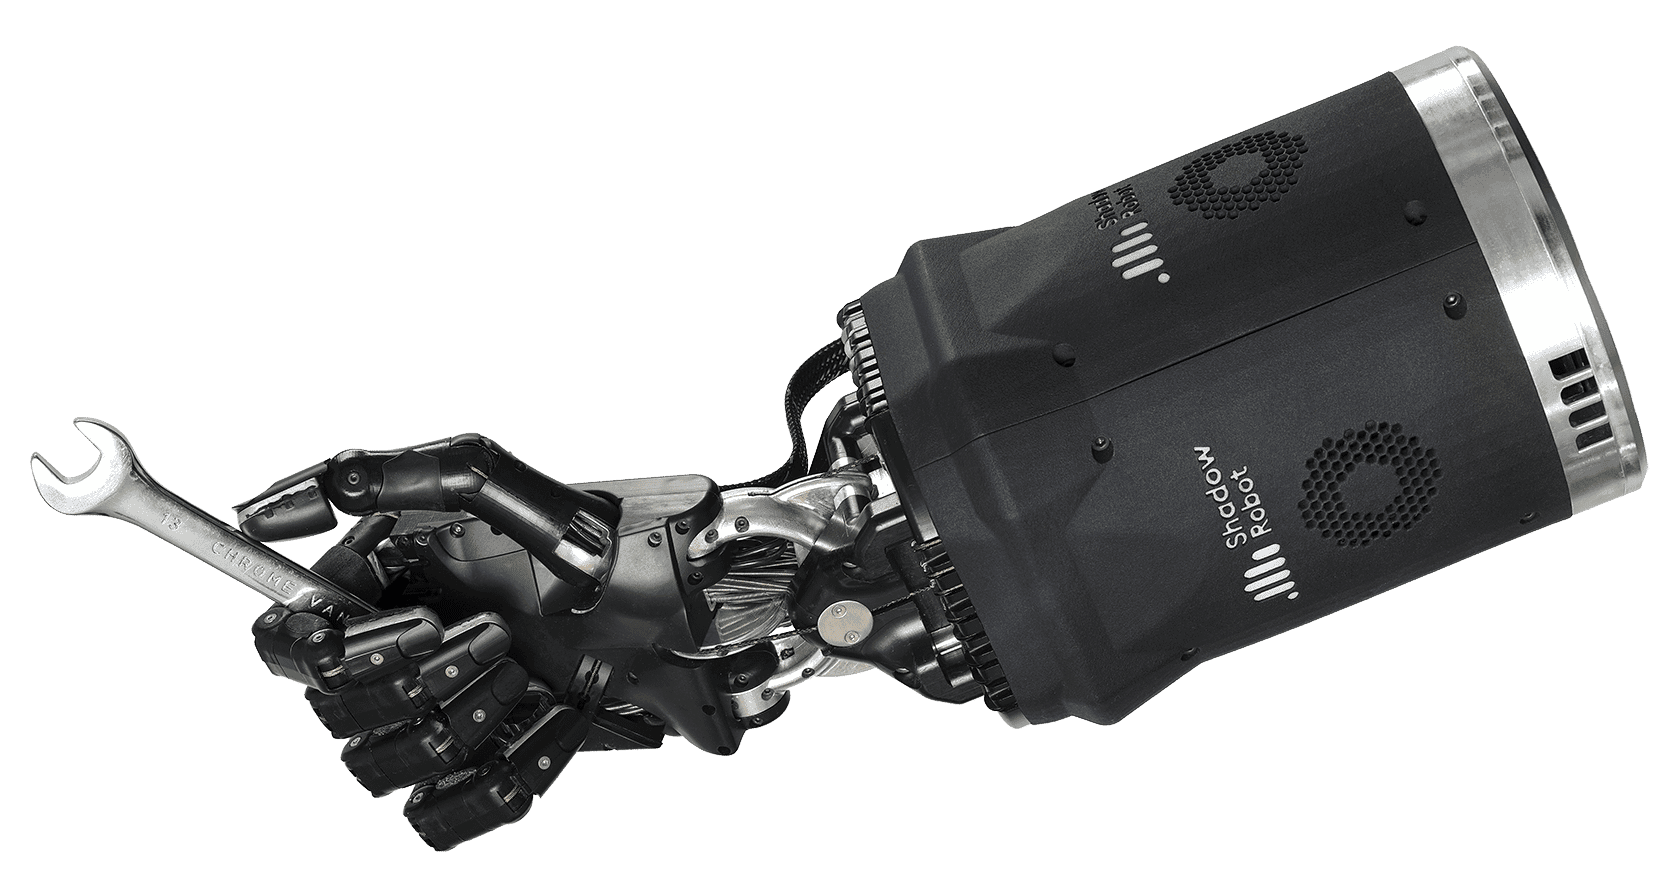
Shadow Dexterous Hand
20モーター・24関節と100超のセンサーを備え、1kHz制御に対応する5指ロボットハンド。
20 motors, 24 joints, 100+ sensors; the standard at research labs worldwide.
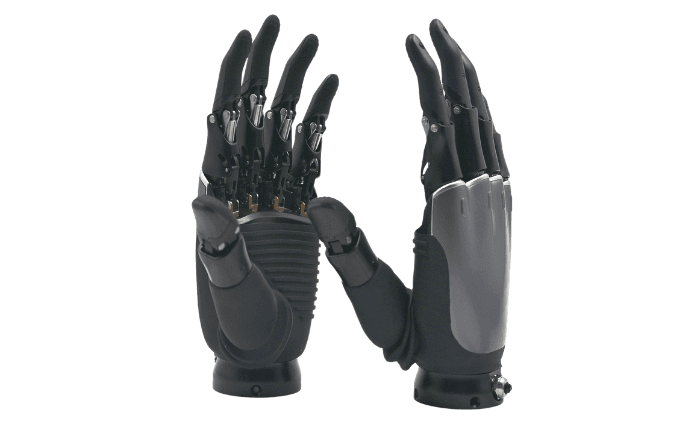
ROH-AP002
指・掌の3次元力覚と150Hz触覚更新に対応する11関節ロボットハンド。
3D force on fingers and palm with 150 Hz touch; an accessible start for tactile research.
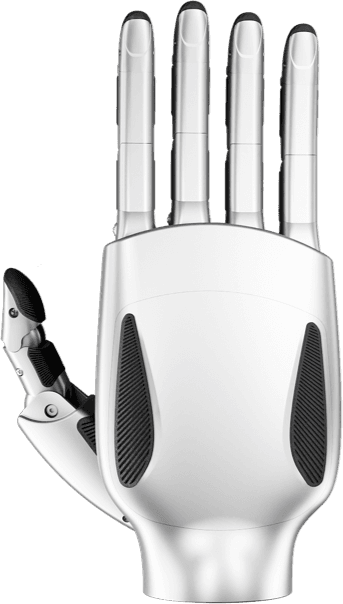
Linker Hand L20
16能動+5受動自由度、触覚・視覚拡張に対応する多指ハンド。
16 active DoF with tactile and vision options; for teleoperation and data collection.
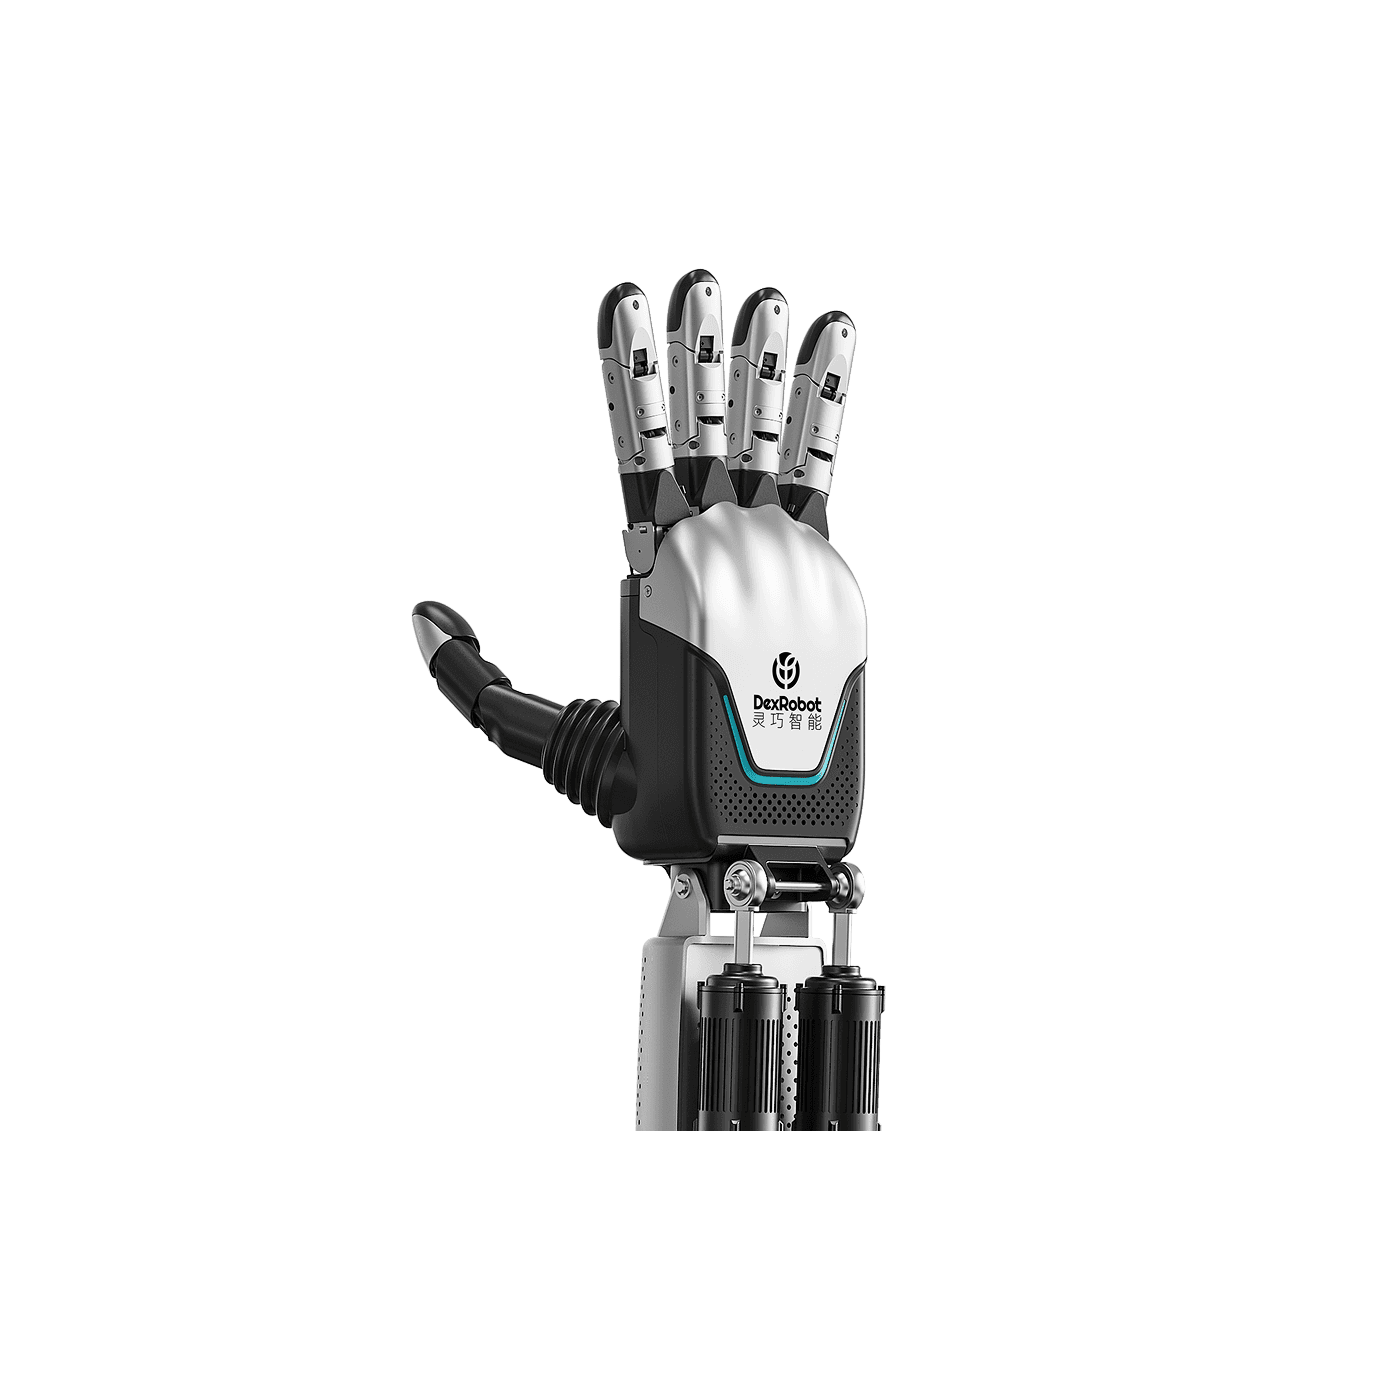
DexHand021 Pro
手首一体構造と全域マルチモーダル知覚を備えた22自由度ロボットハンド。
Wrist-integrated, 22 DoF with full-coverage multimodal sensing for advanced dexterity research.
Not sure which one fits?
Tell us your site conditions and we will narrow candidates and plan a PoC.